Watch: Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics
The project video starts automatically in muted mode where the browser permits autoplay. Use the player controls to enable sound, pause, seek or replay while reviewing the model workflow and simulation results.
Simulation Images and Output Snapshots
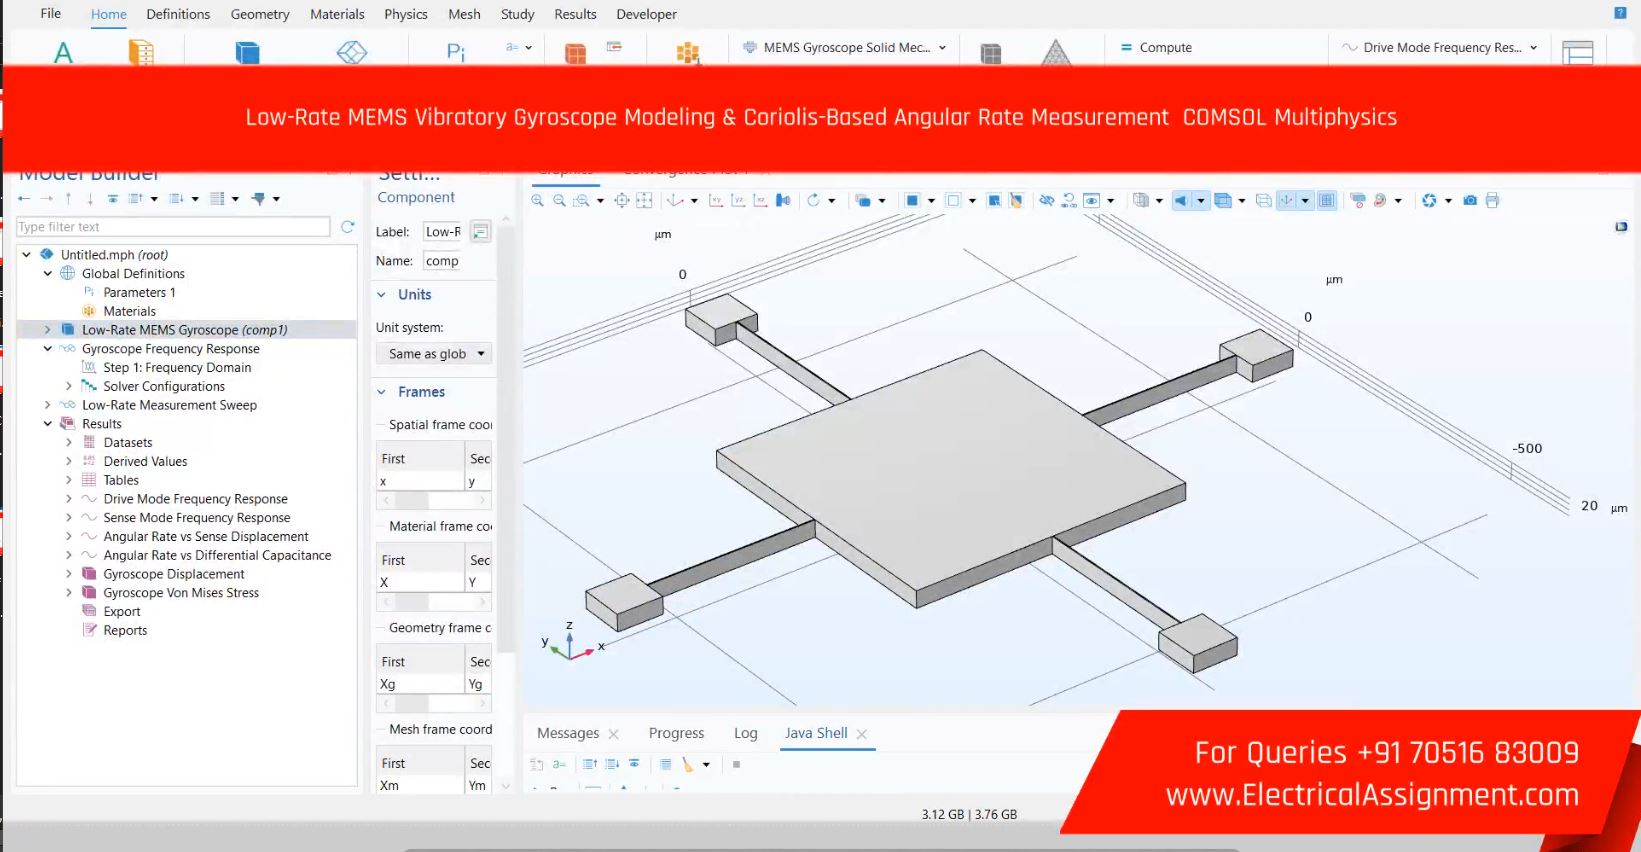
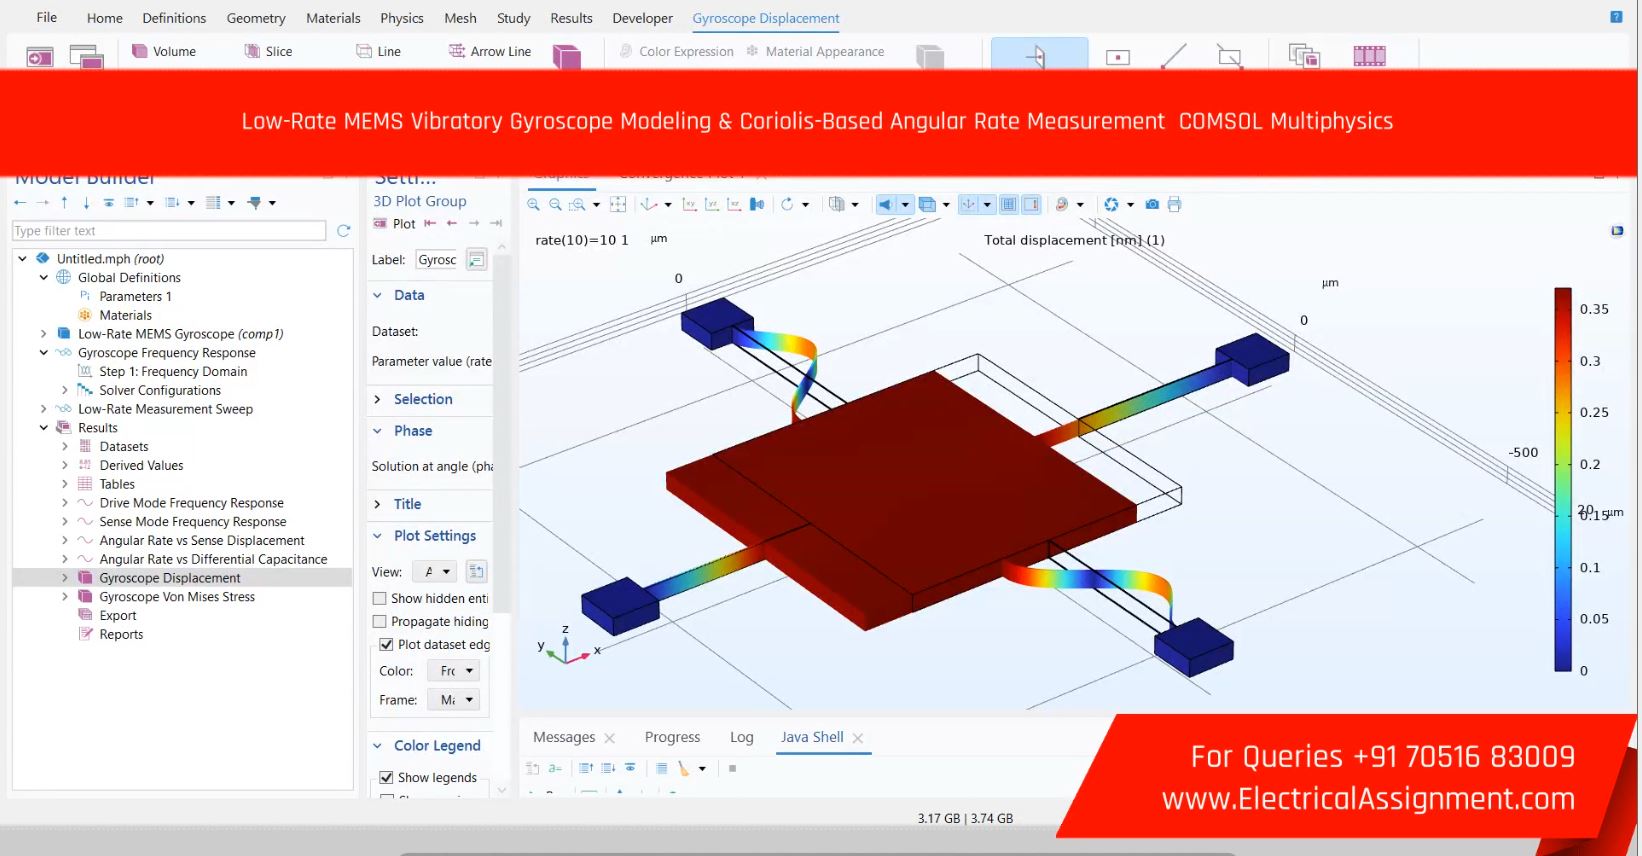
The project images present model architecture, output waveforms, field plots or result snapshots associated with the same technical topic and simulation workflow.
Project Overview and Research Objective
Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics is positioned as a MEMS Gyroscopes & Inertial Sensors study within COMSOL Projects. Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics is classified under COMSOL Projects with a technical focus on MEMS Gyroscopes & Inertial Sensors. Using COMSOL Multiphysics, MEMS Module, the page concentrates on MEMS vibratory gyroscope modal dynamics, Coriolis coupling, mode matching, electrostatic tuning and capacitive sensing. The model is treated as a research experiment in which assumptions, parameters, operating cases and outputs must remain traceable from input to conclusion. Key title concepts include Low-Rate, MEMS, Vibratory, Gyroscope, Coriolis-Based, Angular, Rate.
A suitable research question is: how can the MEMS Gyroscopes & Inertial Sensors approach represented by “Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics” be evaluated using COMSOL Multiphysics, MEMS Module so that drive-sense frequency split and sense displacement per angular rate are improved or maintained without creating unacceptable degradation in scale factor / sensitivity?
The scope is especially relevant to researchers working with COMSOL Multiphysics, MEMS Module who need a traceable link between the implemented model, the operating scenarios and the evidence used in the final thesis or paper.
System Architecture and Main Components
For this topic, the model architecture should make the relationship between the research input, the physical or numerical plant and the reported outputs explicit.
- Drive resonator / proof mass: configure this element so its parameters and role can be traced to the MEMS Gyroscopes & Inertial Sensors objective of Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
- Sense resonator / orthogonal mode: configure this element so its parameters and role can be traced to the MEMS Gyroscopes & Inertial Sensors objective of Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
- Suspension springs and anchors: configure this element so its parameters and role can be traced to the MEMS Gyroscopes & Inertial Sensors objective of Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
- Electrostatic drive / tuning electrodes: configure this element so its parameters and role can be traced to the MEMS Gyroscopes & Inertial Sensors objective of Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
- Capacitive sense electrodes: configure this element so its parameters and role can be traced to the MEMS Gyroscopes & Inertial Sensors objective of Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
- Eigenfrequency, frequency-response and angular-rate post-processing: configure this element so its parameters and role can be traced to the MEMS Gyroscopes & Inertial Sensors objective of Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
Simulation and Research Methodology
- Create the gyroscope geometry, materials and mechanical constraints. Record the assumptions and the evidence expected from this step for Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
- Identify drive and sense eigenmodes and quantify frequency split. Record the assumptions and the evidence expected from this step for Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
- Apply drive excitation and damping / Q assumptions. Record the assumptions and the evidence expected from this step for Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
- Introduce angular rate through Coriolis coupling. Record the assumptions and the evidence expected from this step for Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
- Evaluate sense displacement, scale factor, tuning sensitivity and capacitive-readout response. Record the assumptions and the evidence expected from this step for Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics.
Recommended Study Cases
A thesis or journal-oriented implementation should not rely on a single nominal run. For this project, useful test cases include:
- baseline eigenmode identification
- drive excitation at resonance
- angular-rate sweep through the low-rate range
- electrostatic tuning / mode-matching sweep
- damping, Q-factor or fabrication-parameter robustness case
Validation Metrics and Thesis Evidence
The recommended validation evidence includes drive-sense frequency split, sense displacement per angular rate, scale factor / sensitivity, quality-factor / damping sensitivity. A defensible result section should report both waveform or field behaviour and numerical metrics, with the baseline and proposed cases evaluated under the same conditions. The final discussion should also explain sensitivity to angular-rate sweep through the low-rate range, electrostatic tuning / mode-matching sweep.
Expected Simulation Outputs
- Drive and sense eigenfrequencies — interpret this result against the selected operating case and one of the defined validation metrics.
- Mode shapes and frequency split — interpret this result against the selected operating case and one of the defined validation metrics.
- Coriolis-induced sense displacement — interpret this result against the selected operating case and one of the defined validation metrics.
- Frequency-response amplitude / phase — interpret this result against the selected operating case and one of the defined validation metrics.
- Angular-rate sensitivity and capacitive readout metric — interpret this result against the selected operating case and one of the defined validation metrics.
Video Summary and Technical Context
The project video for Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics should be read together with the technical text on this page. The expected workflow begins with the Drive resonator / proof mass, proceeds through Sense resonator / orthogonal mode and Suspension springs and anchors, and then records Drive and sense eigenfrequencies, Mode shapes and frequency split, Coriolis-induced sense displacement. For a research implementation, the important point is not only that the model runs, but that every output is linked to a stated objective, operating case and validation metric.
The video and page together emphasize MEMS vibratory gyroscope modal dynamics, Coriolis coupling, mode matching, electrostatic tuning and capacitive sensing. Researchers should retain the model parameters, software version, solver/controller settings and the conditions associated with each plotted result so that the work can be reproduced or extended later.
Research Applications
The modelling approach used in Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics can be relevant to the following application directions:
- inertial measurement units and navigation
- low-rate orientation sensing
- automotive / robotics motion sensing
- high-sensitivity MEMS sensor research
PhD Novelty and Publication-Oriented Extensions
A stronger research contribution should extend the baseline topic with a clearly stated limitation, proposed modification and measurable comparison. Project-specific directions include:
- adaptive mode matching under temperature / fabrication drift
- closed-loop force-rebalance or Q-control strategy
- nonlinear and electrostatic-softening compensation
- noise-aware capacitive readout and experimental / reduced-order validation
International PhD and Postgraduate Research Use
For PhD researchers and postgraduate scholars working internationally, this topic can be adapted to a university proposal, published reference paper or independently defined research gap. The model scope can be aligned with the required software version, parameter set, dataset, disturbance profile, geometry, controller structure and reporting format while preserving reproducibility and clear technical attribution.
Electrical Assignment supports research planning and simulation customization for scholars in UK, Australia, Germany, France, Malaysia, UAE and Canada and other regions. The technical objective remains the same: make the simulation understandable, measurable and defensible rather than relying on screenshots alone.
Technical Scope and Related Concepts
Key concepts connected to this project include Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics; MEMS Gyroscopes & Inertial Sensors PhD simulation; COMSOL Multiphysics, MEMS Module thesis research project; COMSOL Projects simulation for postgraduate research; Low-Rate, MEMS, Vibratory, Gyroscope, Coriolis-Based, Angular, Rate engineering simulation; MEMS Gyroscopes & Inertial Sensors methodology and validation. These topics help position the model within its wider engineering research area and support comparison with related methods and applications.
Related Research Articles for This Project
Explore focused articles covering design, optimization, validation, applications and thesis novelty for this same project topic.
Project Media, Research Guides and Related Resources
More MEMS Gyroscopes & Inertial Sensors projects
More projects in this engineering domain
Explore Other Engineering Project Domains
Academic and Project Content Note
This page provides a representative simulation project overview and research-planning framework. Final implementation, numerical claims and documentation should follow the selected source paper, dataset, equipment ratings, software version and university requirements.
Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics research questions
What is the research objective of Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics?
A suitable research question is: how can the MEMS Gyroscopes & Inertial Sensors approach represented by “Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics” be evaluated using COMSOL Multiphysics, MEMS Module so that drive-sense frequency split and sense displacement per angular rate are improved or maintained without creating unacceptable degradation in scale factor / sensitivity?
Which outputs should be validated for this project?
The recommended evidence includes drive-sense frequency split, sense displacement per angular rate, scale factor / sensitivity, quality-factor / damping sensitivity, mode-matching error, linearity across angular-rate range. The exact set should be aligned with the selected paper, model and research question.
Which operating cases should be tested?
A robust study can include baseline eigenmode identification, drive excitation at resonance, angular-rate sweep through the low-rate range, electrostatic tuning / mode-matching sweep, damping, Q-factor or fabrication-parameter robustness case. The same cases should be applied to baseline and proposed methods where a comparison is claimed.
How can Low-Rate MEMS Vibratory Gyroscope Modeling & Coriolis-Based Angular Rate Measurement COMSOL Multiphysics be extended for PhD or journal research?
Relevant directions include adaptive mode matching under temperature / fabrication drift, closed-loop force-rebalance or Q-control strategy, nonlinear and electrostatic-softening compensation, noise-aware capacitive readout and experimental / reduced-order validation. The extension should address a defined literature limitation and be validated quantitatively.
Which software is associated with this project?
The project is associated with COMSOL Multiphysics, MEMS Module in the MEMS Gyroscopes & Inertial Sensors area. Software version, solver settings and dependencies should be recorded for reproducibility.